ME2120 - Dynamics
 Watch on YouTube →
Overview
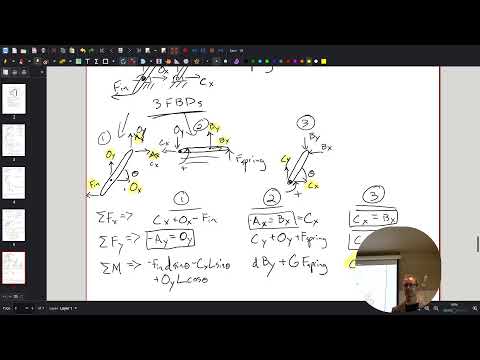
Ryan Cooper uses a gripper mechanism to show how splitting a constrained assembly into separate free-body diagrams reveals the internal reactions needed to solve its kinetics. Under a quasi-static assumption, force and moment balances across three moving components produce nine equations for nine unknowns, which can connect the input normal force to the spring force; the spring force is determined by Hooke’s law, Fspring = kΔx.
Key takeaways
- A constrained gripper that appears underdetermined as a single body, with three equations and five unknowns, can become solvable when divided into separate free-body diagrams.
- Internal joint forces must appear as equal-and-opposite pairs on the bodies they connect, allowing force-balance equations to eliminate reaction components.
- The gripper analysis uses a quasi-static approximation: set force and moment sums to zero when motion is slow and applied forces dominate the bars’ weight.
- Moment equations depend on the perpendicular distance from each force’s line of action, so the mechanism angle θ determines sine and cosine terms through the link geometry.
- A bar whose endpoint reactions align along its axis behaves as a two-force member, an outcome that can be confirmed by solving the component equations.
- Once the mechanism geometry determines spring compression Δx, Hooke’s law, Fspring = kΔx, supplies the spring force needed to relate it to the input normal force.
Chapters
0:00
Case Study Grading and Course Updates
- Ryan Cooper says Case Study 0 has been graded, with feedback available for students who want to revise.
- He plans to check with the TAs about the delayed grading and return of Case Study 1.
2:00
The Gripper’s Three Equations and Five Unknowns
- The gripper’s initial whole-system force and moment balances provide three equations but leave five unknown reaction forces.
- The next step is to divide the mechanism into smaller bodies so internal constraint forces can be solved.
7:00
Splitting the Mechanism to Reveal Internal Reactions
- Cutting the assembly into two parts exposes the reaction forces at their interface.
- Newton’s third law requires each internal force pair to be equal in magnitude and opposite in direction.
- For the initial two-part breakdown, three balance equations per body provide six equations for six unknowns.
14:00
Drawing Free-Body Diagrams for Three Moving Components
- Cooper chooses three moving components and begins drawing a separate free-body diagram for each.
- The diagrams include applied forces, spring force, and pin or joint reactions, with internal forces shown in opposite directions on adjoining bodies.
- The resulting system is framed as a solvable bookkeeping puzzle: the information exists, but it is distributed across the bodies.
18:00
Choosing Force Components Instead of Assuming Resultants
- The OA link diagram uses horizontal and vertical reaction components, with signs reversed on the adjoining body.
- Cooper cautions that a bar’s forces cannot always be replaced by a single resultant along the bar if the bar also carries a moment.
- Keeping reactions as X and Y components is the safer force method when the bar’s internal loading is uncertain.
28:00
Quasi-Static Balances and the Nine-Equation Count
- Separate X-force, Y-force, and moment balances add equations for the three free-body diagrams; the resulting count is nine equations for nine unknowns.
- The quasi-static model treats the sums of forces and moments as zero, rather than including linear or angular acceleration terms.
- Cooper says this approximation is appropriate when the mechanism moves slowly and applied forces greatly exceed the bars’ weights.
33:00
Eliminating Reactions with Force-Balance Substitutions
- The X- and Y-force equations relate reactions such as AX, BX, CX and AY, BY, CY across the three bodies.
- Equal-and-opposite internal reactions let students substitute one component for another and reduce the number of independent variables.
- Some substitutions reproduce the original whole-system balance, while the separate-body equations still retain additional information.
38:00
Using Link Geometry in Moment Equations
- Moment balances use the mechanism angle θ and link lengths such as L and D to calculate force moment arms.
- Forces are resolved by their perpendicular distances: horizontal components use vertical offsets, while vertical components use horizontal offsets.
- Each body can use a different moment center, such as O, A, B, or C, to simplify its equation.
44:00
Relating Spring Force to Input Normal Force
- The final moment balances show that the reactions at one link can align along the link, indicating a two-force-member pattern in the derived solution.
- With nine equations and nine unknowns, students are asked to derive the relationship between the gripper’s input normal force and spring force.
- The spring force is calculated using Fspring = kΔx; Cooper gives a slot displacement of 10 mm and an example spring compression of 2.3, with units not specified in the transcript.
Summary, takeaways, and chapters were generated by AI from the video's transcript and may contain errors. The video belongs to its creator, Professor Ryan C. Cooper.